Boston Dynamics stated it didn’t got down to construct an advanced hand, however as an alternative a dependable one able to utilizing instruments. | Supply: Boston Dynamics
Boston Dynamics immediately unveiled the latest hand for its Atlas humanoid. The hand has 4 fingers, 13 levels of freedom (DOF), is straight actuated, and is designed for mass manufacturing.
Earlier variations of Atlas’ hand featured seven levels of freedom and have been designed to know a big number of objects, Boston Dynamics stated. With the most recent hand, the corporate is shifting its focus to manipulating these objects.
“We thought-about many, many designs, and there have been many questions like: Do we wish the hand to have one thumb or two thumbs? Do we actually need the hand to have a pinky or not? And most of those don’t have straight solutions,” stated Alberto Rodriguez, director of robotic conduct for Atlas. “There’s at all times some quantity of instinct and experimentation. It boils all the way down to a commerce of various competing goals.”
Boston Dynamics stated the four-fingered hand, which doesn’t have a pinky finger, is constructed for top constancy simulation to allow sim-to-real reinforcement studying (RL). The corporate stated it maintained clear direct actuation on the joints, all with a single actuator kind. As in Atlas’ physique, these actuators are fully encapsulated, with no fragile cables crossing joints.
The brand new hand is able to:
- Sliding the fingertip of the thumb alongside the size and throughout the width of all different fingers
- Dexterous pinch grasps between the thumb and any of the opposite fingers
- Dexterous tripodal grasps
- Triggered device grasps, like drills, energy torque drivers, grinders, nail weapons, and welding torches
The information comes only a week after Boston Dynamics opened its Robotics Metaplant Software Middle (RMAC) at Hyundai Motor Group Metaplant America. The corporate stated the Georgia facility is a coaching heart for integrating Atlas humanoids into mum or dad Hyundai’s automotive manufacturing operations.
Why is Boston Dynamics betting on 4 fingers?
With regards to robotic palms, many firms are attempting to recreate human-like palms as carefully as attainable. So, why didn’t Boston Dynamics take that route?
“There’s no pinky as a result of the crew decided that the extra dexterity and duties you’d be capable of accomplish will not be price the additional complexity of three further levels of freedom, the dimensions, the ability consumption, the entire issues that include including further actuators,” stated Dylan Thrush, a mechanical engineer on the Atlas crew.
Earlier than the design was completed, Zachary Jackowski, Boston Dynamics’ chief product and expertise officer, requested the crew to tape their pinky and ring finger collectively for a day and report again on what they weren’t capable of do. On the finish of the experiment, the crew had agreed the robotic hand didn’t want a pinky.
With 4 fingers and 13 DOFs, the hand is able to in-hand reorientation, restoration from a slipping grasp, and dealing with instruments whereas urgent their triggers.
Dimension was additionally a giant concern. A robotic hand wants to know objects of a wide range of sizes and probably attain into small areas. So it might probably’t be too huge. Moreover, palms which might be extra just like human palms have a smaller cross-embodiment hole from human manipulation information.
So, Atlas’ new hand is comparable in measurement to a big human hand, which closely drives the dimensions of the actuators. Due to a number of distinctive actuation applied sciences, the corporate stated it maintained related power to the earlier hand.
Backdrivability and transparency of the actuators are core to the design philosophy of the complete robotic, Boston Dynamics stated. It permits the corporate to depend on proprioception for agile dexterous behaviors. Complementary to proprioception, Boston Dynamics has geared up the hand with dense strain tactile sensors that cowl the fingertips and palm that make it attainable to select on small contact indicators.
Constructing a hand for simulation studying
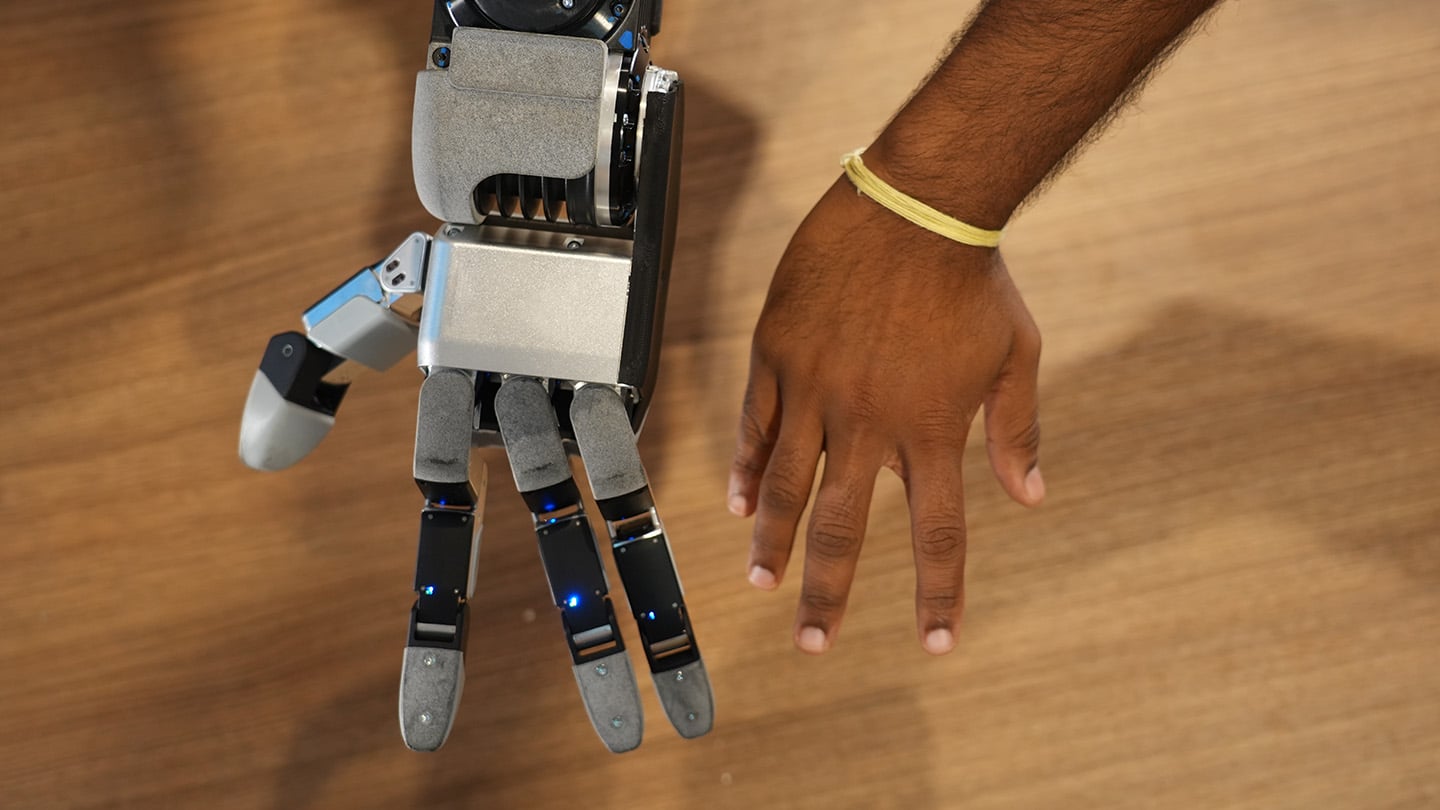
Atlas’ thumb options 4 DOFs, whereas the opposite three options every have three DOFs. | Supply: Boston Dynamics
A few of immediately’s greatest choices for scaling information assortment for manipulation contain Common Manipulation Interfaces (UMIs). With these wearables, demonstrators carry out duties naturally, whereas sensors seize essentially the most related indicators throughout manipulation, like contact occasions and strain distribution.
Direct imitation has its limits, nonetheless, one thing Boston Dynamics stated it discovered in the case of entire physique humanoid management. Entire physique conduct for a humanoid is at all times deployed on prime of a complete physique controller that takes care of the excessive charge dynamics of behaviors equivalent to balancing, restoration steps when tripping, and compensation for forces like gravity, self-collisions or exterior shoves. Importantly, immediately these entire physique controllers are at all times educated with RL in simulation.
Boston Dynamics stated human demonstrations are greatest suited to capturing the visible complexities of a scenario. However, at its core, quick and agile dexterous manipulation can also be a byproduct of high-rate closed-loop management and drive regulation. That is one thing wearable units don’t seize. So, the corporate believes that RL in simulation is a vital part to resolve dexterous manipulation.
This has had a big affect on the design of the hand. Boston Dynamics stated, in some ways, it constructed the hand for sim2real switch and RL. The rigid-drive actuation and backdrivable transmission, together with controls innovation to compensate for cogging and friction, makes it attainable to simulate the hand with excessive dynamic constancy.
This constancy in flip makes RL simpler at coaching strong management insurance policies with publicity to randomizations of motor torque profiles, floor friction coefficients, object geometries, and job disturbances.
The corporate has preliminary outcomes displaying promising sim2real switch in dynamic duties. These behaviors are educated straight in simulation with area randomization and rolled out in {hardware} relying solely on excessive charge actuator proprioception for suggestions.
Editor’s word: Brendan Schulman, vp of coverage and authorities relations at Boston Dynamics, will take part in a panel on “Reshoring With Robots: A Coverage Dialogue” at RoboBusiness 2026, which will probably be on Oct. 20 and 21 in Santa Clara, Calif. Register now to attend.
 Register now and assist us have fun 20 years of RoboBusiness!
The publish Boston Dynamics drops pinkie on new humanoid hand appeared first on The Robotic Report.