Boston Dynamics has unveiled a brand new four-finger hand for its Atlas humanoid robotic, designed to mix the dexterity wanted for advanced manipulation and gear use with the energy and sturdiness required for industrial work.
The brand new hand has 13 levels of freedom (DOF), together with a four-DOF opposable thumb, and makes use of direct actuation along with dense tactile stress sensors throughout the fingertips and palm.
Boston Dynamics says the design allows Atlas to carry out advanced manipulation duties together with in-hand object reorientation, pinch and tripodal grasps, restoration from slipping objects, and operation of instruments reminiscent of drills, energy torque drivers, grinders, nail weapons and welding torches.
The corporate intentionally selected 4 fingers relatively than making an attempt to breed the five-finger human hand, arguing that eliminating the pinky reduces value, dimension, actuator rely and potential failure factors with out considerably decreasing performance.
From greedy to manipulation
Atlas’ earlier seven-DOF palms had been primarily designed to know a variety of objects. Boston Dynamics says the brand new era has been developed to control them.
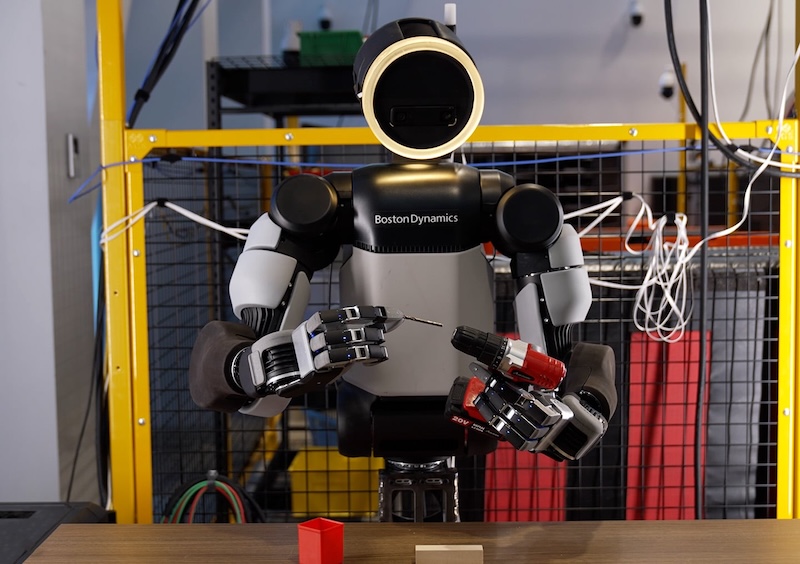
Every of the three fingers has three levels of freedom, whereas the opposable thumb has 4. The thumb can slide alongside each the size and width of the opposite fingers, permitting Atlas to kind totally different pinch and tool-holding configurations.
The hand is roughly the dimensions of a big human hand, partly as a result of Atlas is meant to function in environments, areas and workstations initially designed for folks.
Regardless of the elevated dexterity, Boston Dynamics says the brand new hand maintains comparable energy to its earlier design. The corporate has beforehand demonstrated Atlas carrying a loaded minifridge weighing greater than 100 lb.
The actuators are encapsulated and use a single actuator sort, with no cables crossing the joints. Boston Dynamics says this structure is meant to enhance ruggedness, manufacturability and repairability as humanoid robots transfer towards larger-scale manufacturing.
Why Atlas solely has 4 fingers
Boston Dynamics says the choice to omit the fifth finger adopted inner experimentation over whether or not a pinky offered sufficient further performance to justify the added complexity.
Throughout improvement, chief expertise officer Zack Jackowski requested members of the group to tape their pinky and ring fingers collectively for a day and report which duties they may now not carry out.
The experiment helped persuade the event group that 4 fingers had been ample for the capabilities it was focusing on.
Including one other finger would require three further actuators, growing the hand’s value, quantity and variety of potential failure factors.
The ensuing four-finger structure can nonetheless carry out in-hand reorientation, get well from slipping grasps and maintain instruments whereas working their triggers.
Tactile sensing for industrial work
The hand incorporates dense stress tactile sensors masking its fingertips and palm, complementing the proprioceptive sensing offered by its actuators.
Boston Dynamics says this permits Atlas to detect small contact alerts whereas interacting with objects and supplies the suggestions required for extra delicate manipulation.
Backdrivability and actuator transparency are additionally central to the design, enabling the robotic to make use of proprioception for agile manipulation and pressure regulation.
Instrument use is a selected focus.
Somewhat than making an attempt to create a hand able to performing each process instantly, Boston Dynamics sees instruments as a approach of extending the capabilities of humanoid robots in a lot the identical approach they lengthen human capabilities.
The corporate argues that this can turn into more and more essential as humanoids transfer past standard pick-and-place operations into duties involving meeting, cables, instruments and objects offered in much less structured environments.
Designed for reinforcement studying and simulation
The hand has additionally been designed particularly with simulation and reinforcement studying in thoughts.
Boston Dynamics says its rigid-drive actuation, backdrivable transmission and management techniques enable the bodily habits of the hand to be reproduced with excessive constancy in simulation.
This allows reinforcement studying techniques to coach manipulation insurance policies whereas various elements together with motor torque, floor friction, object geometry and disturbances earlier than transferring these behaviors to the bodily robotic.
The corporate says it has already achieved preliminary sim-to-real ends in dynamic manipulation duties, with behaviors educated fully in simulation after which deployed on Atlas {hardware} utilizing high-rate actuator proprioception for suggestions.
Boston Dynamics sees reinforcement studying as an essential complement to human demonstration knowledge. Human demonstrations can present giant quantities of details about how objects are manipulated, whereas simulated reinforcement studying can prepare the high-speed management and pressure regulation required to execute these actions reliably on a robotic.
The hand has been developed as a companion to the newest era of Atlas, Boston Dynamics’ totally electrical humanoid robotic, which the corporate is growing for industrial purposes and eventual large-scale manufacturing.
Boston Dynamics says dexterous software use shall be a core functionality if humanoid robots are to turn into versatile machines able to performing a broad vary of real-world industrial duties.