The Atlas humanoid robotic doing a cartwheel. | Supply: Boston Dynamics
Robots have captured our creativeness. Now we have seen humanoids balancing on one leg, doing backflips, folding laundry, and transferring easily over troublesome terrain. That is all conduct that only some years in the past appeared like one thing out of science fiction. These viral examples matter as a result of they present that embodied AI has reached a brand new technical stage.
On the identical time, the window on what qualifies as a “humanoid robotic” appears to be shifting. Robotic firms are including wheels, extra sensors, new manipulators, hats, and screens, whereas they take away eyes and heads from their humanoid robotic designs.
As an engineering ecosystem working straight alongside humanoid builders to unravel core {hardware} bottlenecks, we see a recurring theme. The business steadily will get caught up in “robot-forward” pondering. We construct a rare bodily platform first, then scour industrial websites for a job for it to carry out.
If we wish to transfer bodily AI from social media feeds to a sustained industrial degree, we should reverse our present method. The business wants a design technique that works backwards from the workflow. Start with a job that has financial worth. Take into account whether or not a robotic can perform that job higher than a human can.
Then, go backwards to seek out out precisely what {hardware}, sensing capabilities, and kind issue are literally wanted to hold out the duty.
The sensor stack is born within the job, not the datasheet
Profitable industrial robotic types comply with their capabilities. Supply: Vishay Precision Group Inc.
In case you begin by designing a platform, you’ll probably find yourself with a compromised {hardware} stack. The particular workflow determines the machine’s engineering necessities.
Let’s take for instance a bipedal humanoid robotic that’s requested to hold out two totally different industrial work processes. One includes inserting a pin on an automotive meeting line and the opposite includes packing a pallet in a logistics heart.
A pin connector insertion job typically includes a 20 µm clearance and 5 N mating drive. So, there must be contact-force decision beneath 0.1 N and a management bandwidth quick sufficient to detect jamming earlier than a delicate pin bends.
But, when utilizing the identical arm for bulk pallet packing, you want virtually none of that high-frequency micro-force decision. As a substitute, you want heavy payload capability, structural rigidity, and the flexibility to endure 1 million cycles with out baseline mechanical drift.
If you’re constructing a general-purpose platform, a single “middle-of-the-road” drive sensor might lead to a system that would make exact pin insertion troublesome. The system might additionally lack the sturdiness wanted for steady heavy lifting.
The workflow additionally determines your error price range. That is the one issue that turns drive sensing from a value merchandise into one thing that gives a demonstrable return on funding.
Makes an attempt to enhance drive sensing typically fail. For instance, our assessments have proven that utilizing a particular calculation sustaining contact drive at ±0.2 N, can cut back connector scrap in quantities from 1.2% to 0.5%. This could translate into annual estimated financial savings of roughly $450,000 per meeting line. This type of financial argument is just attainable in case you start with the duty in query.
That’s precisely the explanation why the number of essential elements, for instance these based mostly on pressure sensing, should happen on the architectural design stage reasonably than being handled as an afterthought when getting ready the invoice of supplies (BOM).
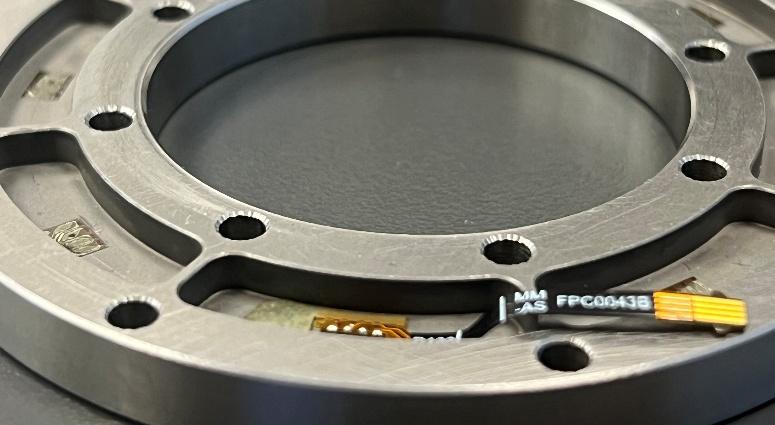
Pressure sensing can present precious information if integrated early in designs. Supply: Vishay Precision Group
Adjusting the robotic reasonably than adjusting the ability
The tendency to deal with the duty first raises the principle query about kind issue. Is a specialised kind issue the higher selection? When is a humanoid design strictly needed?
Working environments could be divided into two varieties: greenfield and brownfield. The actual problem just isn’t what the robotic ought to appear like, however whether or not it’s cheaper to change the robotic or to change the ability.
With greenfield websites, you should use specialised robots. With brownfield websites, like an current refinery or chemical plant, the robotic has to adapt to areas created for people.
In greenfield builds, like Equinor’s Northern Lights facility, the operator can design the format from the start and assemble the ability across the job. So, specialised, non-humanoid types virtually at all times show higher by way of unit economics, pace, and power effectivity. Legged and wheeled robots are extra dependable for the varieties of duties they perform.
Nevertheless, generally, industrial actions happen in brownfield websites, the place the one sensible possibility is to adapt the prevailing platform. These websites have slim aisles, stairs, flooring grating, and doorways designed with the human physique in thoughts. On this state of affairs, a human-suitable kind issue, whether or not that includes legs, two arms, or a humanoid form, turns into a significant benefit. It lets the gear function in environments designed for individuals with out spending tens of millions of {dollars} retrofitting the amenities.
The true check for a humanoid design is whether or not, in case you have been beginning once more, you’d nonetheless go together with a humanoid. When human compatibility is required, the fundamental bodily necessities keep the identical: foot contact, joint torque, and wrist drive.
The robots might come in numerous shapes, however they’ve the identical sensory physics. Pressure-based sensing endures even when the shape issue modifications, providing basic ground-truth measurement no matter how your bodily platform develops.
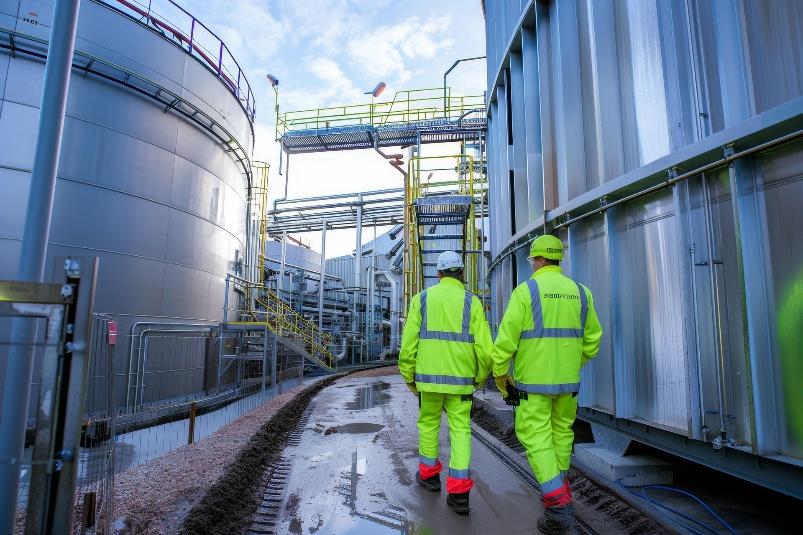
One check for humanoids is whether or not human compatibility is required. Supply: Vishay Precision Group
Deployment depth beats demo breadth
Flashy viral movies present what’s technically attainable. The true check, nevertheless, just isn’t the demonstration itself however the second buy order. Solely by means of repeat orders can enterprise utility be confirmed.
Though demonstrations utilizing items calibrated underneath climate-controlled situations show a robotic can perform as soon as, full fleet deployment calls for that the robotic survive no less than 10,000 cycles per shift amid fixed thermal variation and with near-zero tolerance for drift.
Most bodily AI tasks fail as a result of the engineering effort turns as an alternative to broad, common guarantees earlier than addressing particular operational details. In real-world conditions, deployments fail attributable to drift, sensor fatigue, and recalibration challenges, not flaws in reasoning.
Editor’s notice: Humanoids and bodily AI are among the many session monitor matters at RoboBusiness 2026, which can be on Oct. 20 and 21 in Santa Clara, Calif. Register now to attend.
 Register now and assist us have a good time 20 years of RoboBusiness!
The bodily AI stability sheet
Integrating AI into bodily {hardware} requires a disciplined stability between energy consumption, thermal dissipation, mechanical put on, and security limitations. With software program, you scale by making copies; with {hardware}, it’s important to purchase it, construct it, and wait.
Groups that take a software program method typically fail to account for this bodily stability sheet. Past primary thermal or electrical limits, non-linear actuator gear reductions introduce advanced behaviour that’s notoriously troublesome to foretell and simulate.
True backdrivability solves a part of this downside by permitting the robotic actuator or joint to totally replicate any bodily influence from the atmosphere again to the core management structure.
Regardless of the {hardware} bottleneck could also be, whether or not it’s thermal throttling within the joint actuators or the quantity of energy drawn underneath peak load, every constraint comes right down to the identical want: figuring out precisely what drive is current underneath precise loading situations, at actual temperatures, over a interval of years. That is the data that strain-based sensing gives, which is why it ought to be included within the structure and never simply listed within the invoice of supplies.
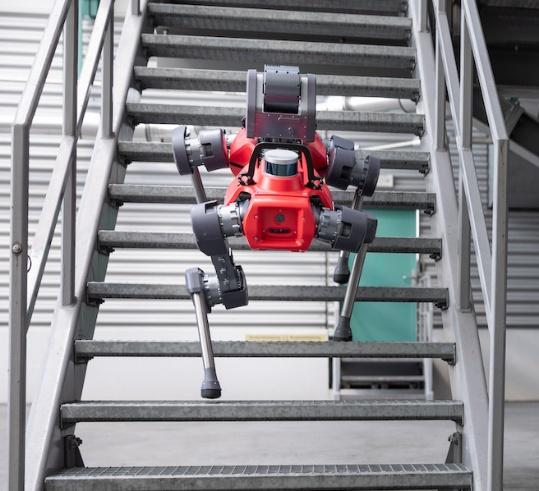
Robotic security requires greater than software program, in keeping with Vishay Precision Group. Supply: ANYbotics
The actual metrics of business viability
To evaluate the industrial viability of bodily AI techniques, we must always transcend slick-looking advertising movies. As a substitute, we must always deal with the metrics that finance groups truly care about.
Crucial and important metric is imply time between interventions (MTBI). This may be thought of essentially the most real measure used within the business, however is the one that’s least typically revealed. If a human operator has to intervene each 20 minutes to unjam a gripper or reset a drifted sensor, then excessive autonomy figures have little significance.
We have to assign the identical significance to the precise value per unit of labor, whether or not calculated on a per-pick, per meter travelled, or per inspection accomplished foundation. This determine finally determines whether or not a robotic fleet will exchange or increase current labour.
Operational worth additionally relies on redeployment time. Deployment time reveals whether or not a “general-purpose” platform can swiftly alter to a brand new job or whether or not reconfiguration requires weeks of customized engineering. Lastly, the variety of security incidents per working hour will decide if the robotic ever goes outdoors of its cage to function freely amongst human employees.
A viral video reveals a robotic able to finishing up a given job as soon as. Nevertheless, a sustainable enterprise wants the robotic to hold out that very same job no less than 10,000 instances in a row, with none intervention, drift, or failure.
The principle conclusion is simple: Begin with the workflow, construct dependable sensing into the core structure, and deal with operational metrics so each specialised machines and humanoid platforms can fulfil their potential within the bodily world.
 In regards to the creator
Ron Zukerman is an innovation director at Vishay Precision Group Inc. (VPG). The corporate is a frontrunner in precision measurement and sensing applied sciences.
VPG stated its sensors, weighing options and measurement techniques optimize and improve clients’ product efficiency throughout a broad array of markets to make the world safer, smarter, and extra productive. To study extra, go to the corporate at www.vpgsensors.com and comply with it on LinkedIn.
The put up Will ‘boring’ robots win in the true world? Why robotic kind ought to comply with workflow appeared first on The Robotic Report.