Skild AI has demonstrated a brand new self-play coaching strategy that allows robots to develop bodily expertise with out counting on human demonstrations, utilizing its S1 robotics basis mannequin to study soccer by way of greater than 140 years of simulated play.
The corporate says the method may finally permit robots to amass more and more complicated expertise in factories, building websites, houses and different bodily environments with out folks having to exhibit each motion.
Skild used Nvidia Isaac Sim to create the simulated surroundings, giving the mannequin a single goal: rating a objective.
Moderately than specifying particular person behaviors akin to dribbling, tackling or recovering after a fall, the researchers allowed the coverage to compete in opposition to progressively extra succesful variations of itself.
Skild says: “The coverage then realized to attain by taking part in in opposition to latest variations of itself. Because it improved, its opponents improved alongside it – turning each acquire in functionality into an more and more tough opponent.”
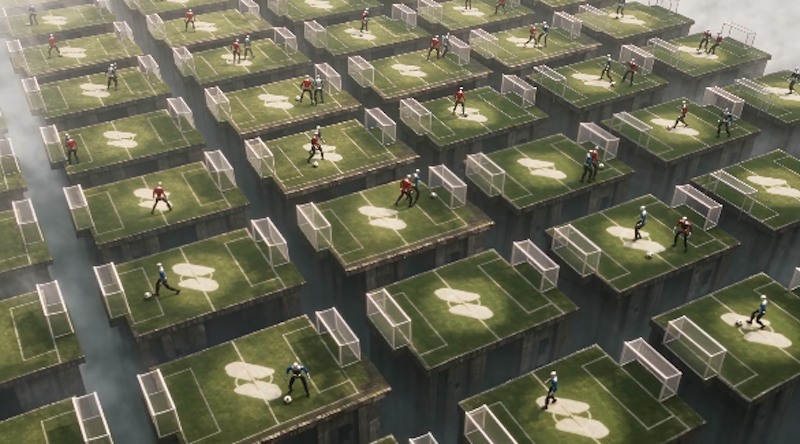
Throughout its first few simulated months, the robotic may barely stroll. As coaching continued, it realized to get well after falling and subsequently developed behaviors together with dribbling round defenders, shielding the ball and tackling opponents.
Based on Skild, these capabilities emerged from the target of scoring fairly than from individually engineered rewards for every habits.
After greater than 140 years of simulated play, Skild transferred the ensuing coverage from simulation to a bodily humanoid robotic and demonstrated it taking part in soccer.
The corporate says: “We see the profitable switch from simulation to humanoid, together with the sheer complexity of the duty, as a vibrant inexperienced flag for self-play on the highway to bodily AGI.”
The work represents a post-training extension of S1, Skild’s robotics basis mannequin, which the corporate launched in August.
S1 is pre-trained utilizing knowledge together with human movies, glove knowledge, simulation and teleoperation, and is designed to study duties from in-context demonstrations.
Skild argues, nevertheless, that coaching primarily from human-generated knowledge finally constrains fashions to the capabilities represented in that knowledge.
The corporate says: “Nonetheless, as a result of S1-class fashions are pre-trained on human knowledge, they’re capped at human functionality. We imagine bodily self-play will allow robots to far exceed human functionality.”
Self-play has beforehand produced important advances in software-based AI methods.
DeepMind used the strategy extensively in its AlphaGo methods, whereas self-play subsequently contributed to methods able to taking part in multiplayer video games together with StarCraft II and Dota 2.
Skild is trying to increase the identical precept into bodily AI, the place robots should study not solely methods but in addition the bodily actions required to execute them in the actual world.
Soccer offers a demanding take a look at as a result of it combines locomotion, manipulation, restoration from bodily disturbances and strategic interplay with opponents.
The corporate says the strategy is just not restricted to sport and is already being prolonged to on a regular basis robotics duties.
Skild can also be experimenting with bigger teams of brokers. Early four-agent soccer experiments have begun to provide behaviors together with passing and coordination, in accordance with the corporate.
Future work is anticipated to discover collaborative manipulation and navigation because the variety of interacting robots will increase.
Skild says: “This simulation ran for over a century with a trivial objective. What occurs once we run it for orders of magnitude longer, on a digital building web site, manufacturing unit, or house?”
The analysis factors towards an alternate method of scaling robotic studying: utilizing human knowledge and demonstrations to ascertain broad foundational capabilities, then permitting robots to enhance these capabilities autonomously by way of giant quantities of simulated expertise.
If the strategy transfers efficiently to sensible duties, it may cut back one of many main bottlenecks dealing with bodily AI – the quantity of human-generated knowledge required to show robots more and more complicated behaviors.