Credit score: Daimon Robotics
Imaginative and prescient has change into central to trendy robotics, however cameras alone can’t inform a robotic every part it must learn about bodily contact. When dealing with versatile objects, inserting elements, or manipulating delicate gadgets, robots want details about forces, slippage, and make contact with that visible methods could miss.
Daimon Robotics needs to supply the infrastructure to assist robots develop that functionality.
Quite than focusing completely on tactile sensors or growing a single basis mannequin, the corporate is constructing a pipeline that connects tactile sensing, information assortment, simulation, and AI fashions. Its purpose is to show bodily interactions into helpful coaching information that helps robots carry out manipulation duties extra reliably.
“By constructing tactile intelligence, we’re truly taking part in the function as an infrastructure supplier,” Daimon’s Accomplice & VP of Know-how Dr. Zhu instructed The Robotic Report. “We’re not aiming to be a basis mannequin developer. We’re offering the infrastructure for doing so for these downstream clients.”
That distinction is central to Daimon’s technique: develop the instruments and information infrastructure that different corporations can use to construct extra succesful robotic methods.
Constructing a pipeline for tactile information
Gathering helpful tactile information at scale presents a problem. In contrast to visible information, which might be captured comparatively simply with cameras, tactile information depends upon bodily contact. The ensuing data varies with an object’s materials, geometry, the forces utilized, and the duty being carried out.
Daimon is growing a pipeline to seize and course of these interactions, with tactile suggestions working at 30 Hz. The corporate can be working to attach real-world information with simulation, permitting bodily interactions to tell coaching in digital environments.
The sim-to-real hole stays a major problem, notably when precisely reproducing bodily properties equivalent to friction and make contact with forces. Daimon’s strategy begins by calibrating simulations towards real-world measurements earlier than transferring collected information into simulated environments.
“Let’s be frank; it’s not ok. It’s form of horrible,” Zhu stated of the present state of simulation, referring to the hole between simulated and real-world environments.
Daimon is growing tactile simulations that account for bodily properties measured by way of real-world testing. The purpose is to enhance the constancy of these simulations and make it simpler to switch realized capabilities to bodily robots.
The corporate has mentioned accumulating greater than 10,000 hours of information, with its longer-term Daimon-Infinity initiative concentrating on greater than 1 million hours of tactile embodied information.
Zhu additionally emphasised the significance of working with corporations growing robotic fashions and functions.
“Doing every part ourselves was not sufficient,” he stated. “Collaborating internationally in several downstream situations is basically necessary.”
That collaboration helps Daimon perceive what different builders want from its sensors, data-collection units, software program, and analysis instruments.
Credit score: Daimon Robotics
From tactile demonstrations to industrial functions
Daimon is concentrating on manipulation duties equivalent to meeting and packaging, the place robots should reply to bodily contact somewhat than merely comply with predetermined trajectories.
A robotic may want to find out whether or not a part is correctly seated, detect when an object slips, or modify its actions when a component behaves unexpectedly. Tactile suggestions can assist it reply to those circumstances.
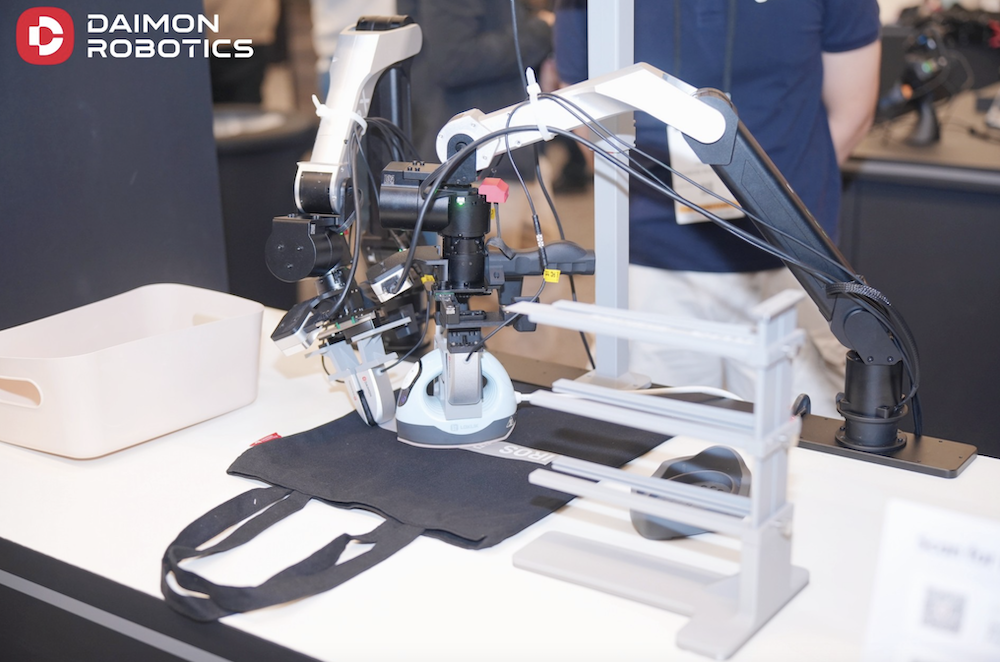
The corporate demonstrated functions involving delicate manipulation at IROS 2026, together with making use of heat-transfer designs to tote baggage and threading bracelets. It additionally confirmed a robotic accumulating and packaging damaged glass, illustrating how fashions educated on information from various situations might be prompted to carry out particular duties.
Daimon makes use of its Umi system to gather information from human interactions. Zhu stated the corporate’s demonstrations had been powered by basis fashions educated on information collected throughout a number of situations, somewhat than being constructed solely round particular person robotic demonstrations.
The corporate has recognized Lenovo Capital and Inovance Know-how as key companions. Zhu stated Daimon has additionally moved past proof-of-concept tasks into industrial meeting traces and warehouses, though he declined to call particular clients due to nondisclosure agreements.
The industrial take a look at is whether or not tactile sensing and the fashions constructed round it may well enhance efficiency constantly in manufacturing environments, the place robots should deal with variations in objects, supplies, and working circumstances.
Shifting past visible notion
Daimon’s broader technique facilities on growing fashions that may use tactile data to know and reply to bodily interactions.
Its Daimon-TWM effort focuses on a tactile-grounded world mannequin meant to assist robots motive about bodily interactions, somewhat than counting on visible notion alone.
Recognizing an object is simply a part of manipulation. A robotic should additionally perceive how its actions have an effect on that object and modify when the bodily outcome differs from expectations. Tactile suggestions can assist shut that loop by offering details about contact and the implications of an motion.
Zhu described two roles for tactile sensing in robotic methods: serving to fashions motive about bodily properties and enabling fast changes throughout contact-intensive duties. The latter can require high-frequency suggestions, with Daimon concentrating on management at 30 Hz.
The corporate can be exploring how information collected by way of human interactions can assist prepare fashions for various robotic configurations, together with humanoids and dual-arm manipulators.
However accumulating information and coaching fashions are solely a part of the issue. Builders should nonetheless reveal that these methods generalize throughout completely different objects, supplies, robots, and working circumstances.
Scaling contact for robotics
The broader query going through the robotics business is what infrastructure is required to make bodily AI work reliably outdoors managed demonstrations.
Firms are investing closely in vision-language-action fashions, simulation, and large-scale robotic coaching datasets. Contact provides one other dimension, notably for robots that should manipulate objects by way of bodily contact.
Daimon goals to construct a part of the infrastructure connecting sensing, information, simulation, and intelligence. Its technique is to help the businesses growing robotic methods somewhat than compete immediately with them to construct the following general-purpose robotic mind.
Its success will depend upon whether or not that strategy measurably improves manipulation, reduces the hassle required to develop new functions, and helps deployments throughout completely different industrial environments.
Zhu was cautious to not overstate the capabilities of in the present day’s fashions. Even when educated on massive datasets, he stated, their capacity to generalize stays restricted.
“The mannequin is just not as clever as we predict,” Zhu stated. “It has some generalization capacity, however it was in-domain generalization generally.”
He added that embodied-intelligence fashions are nonetheless in improvement, and that accumulating information from comparable duties can assist them generalize to new functions.
For Daimon, the problem is popping that rising functionality into dependable efficiency throughout a broader vary of real-world duties.
The put up Daimon Robotics constructing the infrastructure layer for tactile intelligence appeared first on The Robotic Report.