Boston Dynamics mentioned its new hand continues to be able to dealing with over 100 lb. | Supply: Boston Dynamics
Final week, Boston Dynamics Inc. gave a have a look at its new humanoid robotic hand. The four-fingered hand has 13 levels of freedom, or DoF, and is immediately actuated. The corporate mentioned it designed it for mass manufacturing.
Plenty of issues instantly stand out in regards to the hand. Notably, Boston Dynamics has dropped the pinky finger and lowered the scale of the gripper. Much less clearly, the corporate mentioned it constructed the brand new hand for high-fidelity simulation to allow sim-to-real reinforcement studying (RL).
To study extra in regards to the new hand, The Robotic Report spoke with Alberto Rodriguez, the director of robotic conduct for Atlas at Boston Dynamics.
What did Boston Dynamics study from its humanoid trials that it utilized to the brand new hand?
Rodriguez: Having a product roadmap for Atlas has been a key enabler when it got here to creating onerous choices like what’s the proper stage of complexity that we needs to be packing right into a hand and navigating its design tradeoff between dexterity, power, ruggedness, value, reparability, and sensing.
We now have discovered issues from the design of Atlas’ physique. There are issues like simplicity, modularity, and actuator maturity that make sense in idea, however over time, you begin appreciating the large influence they’ve within the velocity you’ll be able to transfer.
A dependable robotic lets you seize knowledge quicker, run extra experiments, and take bets at early deployments. Modularity lets you focus with extra power on a smaller variety of issues that it’s essential to get proper. That additionally lets you transfer quicker.
We now have used the identical philosophy with this hand. It’s constructed out of 13 an identical actuators, all fully encapsulated, with no fragile cables crossing joints, which is already paying off.
We now have additionally discovered, for instance, that the sooner fingers had been robust sufficient to elevate 100 lb.-plus heavy objects, so we didn’t want to extend power, and we might take into account reducing it a bit to additional enhance actuation transparency. We additionally skilled the challenges that earlier fingers had with sure extra complicated duties, which have influenced the present design.
Did you have a look at any off-the-shelf finish effectors, and why did you resolve to construct a hand in-house?
Rodriguez: We all the time have a look at what’s on the market to know the state-of-the-art. Arms are a key piece of expertise which are so integral to the worth proposition of humanoids that it might be very tough for us to strategy it in every other means than in-house.
As we described in our blog post, all fingers come out of a really consequential tradeoff of capabilities, and understanding the way it matches into the product roadmap is essential.
How does Boston Dynamics guarantee sturdiness so the gripper can final by many shifts?
Rodriguez: This isn’t a lot totally different from how we do it for different key applied sciences within the robotic.
All of it begins from an incredible {hardware} design workforce that has finished this many instances earlier than and has constructed instinct for what results in dependable {hardware}.
We even have a robust tradition of collaboration between the conduct and {hardware} groups in these early design phases to lock in key design options, like morphology, sensing, torque distribution, and so on., through the use of strategies like simulation or mockup designs. This permits the {hardware} workforce to enter the detailed design with extra confidence.
We construct early prototypes and put them within the fingers of the programs, controls, and conduct groups for some time to unearth as many as potential of the unknown unknowns and iterate on the design.
Then, we put the fingers and numerous subcomponents by their paces below rigorous validation and verification assessments to test that their conduct is at par with expectations. Whereas that is tedious and would possibly initially decelerate the deployment of latest {hardware}, it finally ends up dashing up the method by permitting to refine points quicker than having to painfully uncover them within the area.
What sorts of duties have you ever been testing with the brand new hand?
Rodriguez: Every kind. It’s tough to outline necessities on a system as complicated as a hand, and one technique to do it’s to construct a collection of consultant duties of what the hand is supposed to do sooner or later. Many of those are frequent industrial duties like utilizing handheld energy instruments, dealing with cables, and fishing for screws.
We now have additionally used these fingers on many duties which are much less mission-oriented, corresponding to bring-up duties that we use to match towards earlier fingers, and in different duties that assist us discover the boundaries of what the fingers are able to.
As all the time, we like taking inspiration from feats of human bodily achievement — corresponding to parkour or gymnastics — to push ourselves and do it in a means that connects with individuals. We now have been enjoying with various kinds of juggling and pace hand video games.
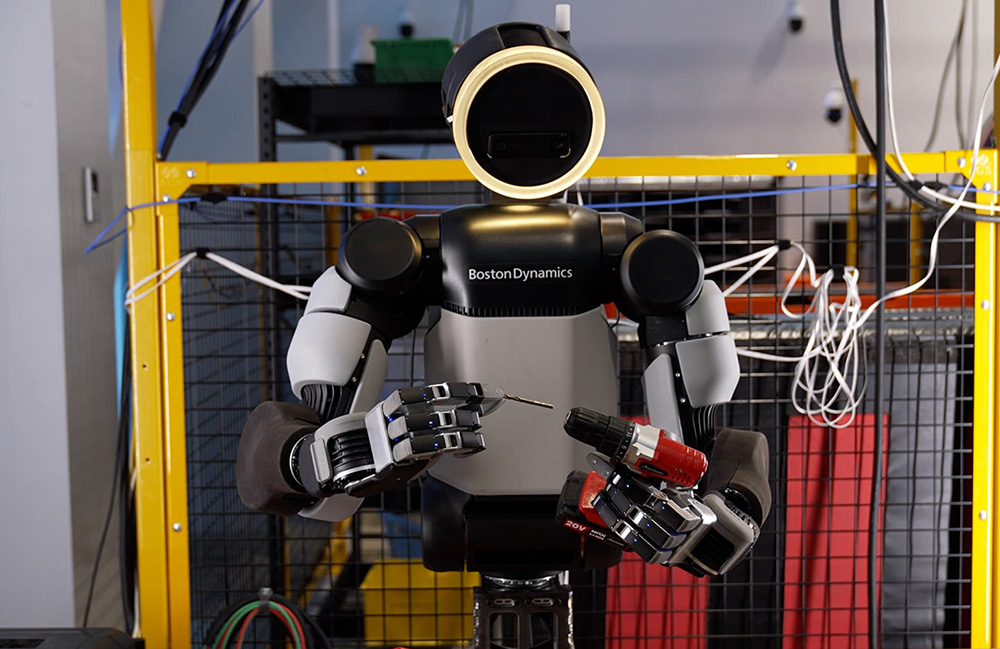
Boston Dynamics mentioned it didn’t got down to construct a sophisticated hand, however as a substitute a dependable one able to utilizing instruments. | Supply: Boston Dynamics
Are you able to inform us extra about Boston Dynamics course of deciding what number of fingers to incorporate on the hand?
Rodriguez: The method depends on instinct, intervals of huge entropy in idea designs, after which a collection of duties or behaviors that we wished the hand to have the ability to do. Our product roadmap offers us concrete manipulation duties that we all know are in scope for Atlas.
Device use is a crucial instance, however there are various extra, from how small are the screws that Atlas ought to have the ability to decide to how small are the areas the place Atlas ought to have the ability to put its fingers in.
One other helpful technique to scope hand necessities is as a set of motions which are necessary for dexterous manipulative conduct, and measure designs towards them. Listed here are a number of the key motions that we targeted on:
- Having the ability to slide the fingertip of the thumb alongside the lengths of the opposite fingers
- Having the ability to slide the fingertip of the thumb throughout the fingers
- Having the ability to rock the fingertip of the thumb towards the index finger in a dexterous pinch grasp
- Having the ability to exert energy grasps on triggered instrument handles
Selections just like the variety of fingers or the variety of joints per finger are tough, however we attempt to preserve a practical perspective and a transparent line of sight to components like value and reliability which are key to have the ability to scale manufacturing.
For instance, a design that had quite a lot of preliminary help was a hand with two thumbs, one on both sides. This design had the additional benefit that you don’t want to have two separate proper and left fingers. You may make them on a single meeting line.
We lastly determined towards it as a result of it entails additional actuation complexity that in the end incurred additional DoFs, value, and quantity.
What in regards to the hand makes it simpler to work with in simulation and for reinforcement studying?
Rodriguez: We design the actuation and transmission with a watch to backdrivability and transparency. On the controls aspect, we’ve got developed strategies to compensate for a number of the remaining non-idealities on the actuators, like compensating for various kinds of friction.
All of this permits correct dynamic simulation, key for the design philosophy of all the robotic. This makes reinforcement studying more practical at coaching insurance policies that may use proprioception, the place the actuators themselves sense that you’re pushing again on them and switch on to {hardware}.
That is the very same recipe that has succeeded for agile humanoid conduct up to now few years. Construct actuators that simulate properly, after which depend on RL at scale.
I’m satisfied that the flexibility to make use of RL in simulation goes to be a key enabler for the subsequent technology of manipulation capabilities for complicated dexterity, going past decide and place. These are duties which are tough to teleoperate or display, as a result of quite a lot of the related data to breed them is within the fast modifications of the distribution of contacts and stress.
Have you ever began testing the hand at RMAC, and what have the outcomes been up to now?
Rodriguez: Not but. We now have used the brand new fingers extensively in our headquarters however haven’t deployed them but to the entire robotic fleet. That could be a course of that requires coordination and time to make it possible for it doesn’t disrupt common operations like knowledge assortment or functions.
Editor’s word: Brendan Schulman, vp of coverage and authorities relations at Boston Dynamics, will take part in a panel on “Reshoring With Robots: A Coverage Dialogue” at RoboBusiness 2026, which will probably be on Oct. 20 and 21 in Santa Clara, Calif. Register now to attend.
 Register now and assist us rejoice 20 years of RoboBusiness!
The submit Boston Dynamics offers extra perception into its redesigned humanoid hand appeared first on The Robotic Report.